

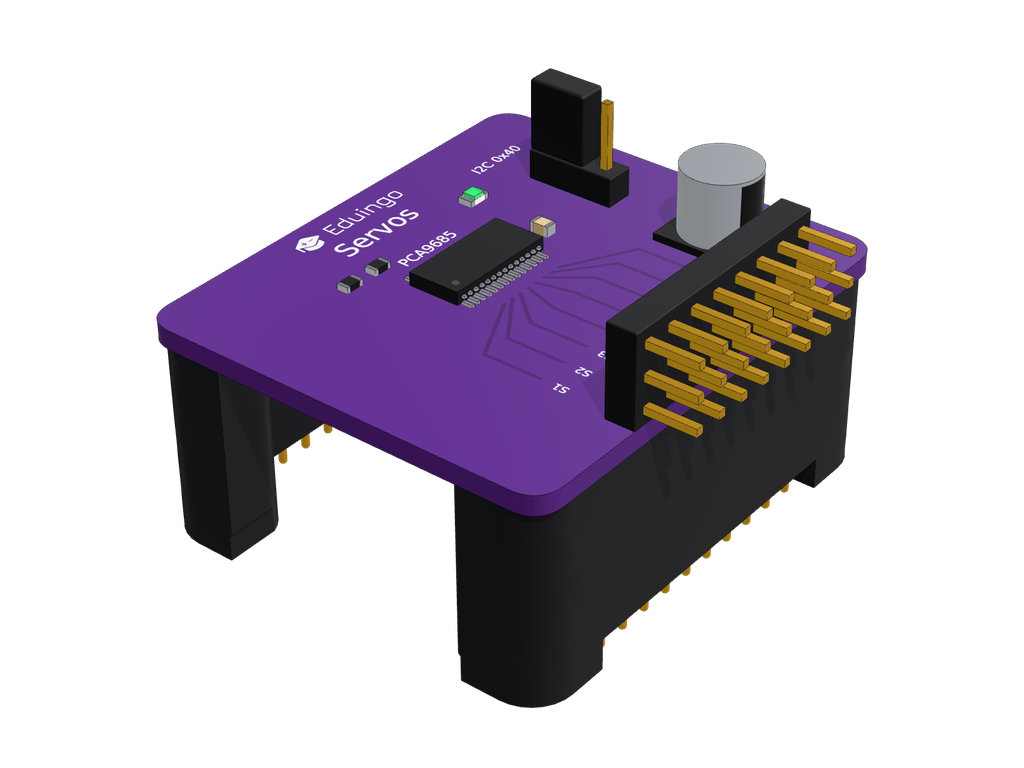
Specifications
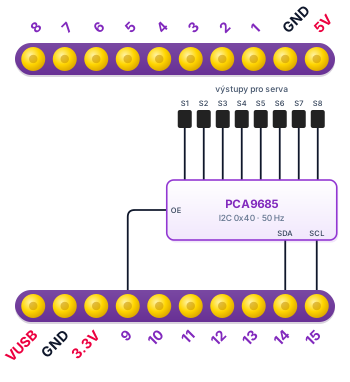
- 8 servo outputs S1–S8 on the side of the board
- PCA9685 driver on I2C, address 0x40
- 50 Hz PWM control
- Adafruit PWM Servo Driver library
- You can stack another module on top of it
- Driver on 3.3 V, servos on 5 V (assumed)
- Driver current ≈ 10 mA, each small servo (SG90) ≈ 100–250 mA while moving and up to ≈ 700 mA when stalled (estimate). A computer USB port safely handles 1–2 moving servos at a time
- The PCA9685 also answers the shared address 0x70 (All Call), so no other sensor in the tower may use it
- Uses: RC cars, robotic arms, smart locks
Pins
| Pin | Function |
|---|---|
| IO9 | OUT_EN, outputs enabled on LOW |
| IO14 | I2C SDA |
| IO15 | I2C SCL |
Wiring diagram
Example code
Try the example Pan and tilt camera right in your browser in Eduingo AI Lab. Put a camera or a torch on two servos. Moving the joystick sideways turns it left and right (servo 1), moving it up and down tilts it (servo 2). Wherever you point the joystick, the camera looks. Pressing the joystick brings it back to straight ahead. The tilt is limited to 30 to 150° so the camera doesn't bump into anything.